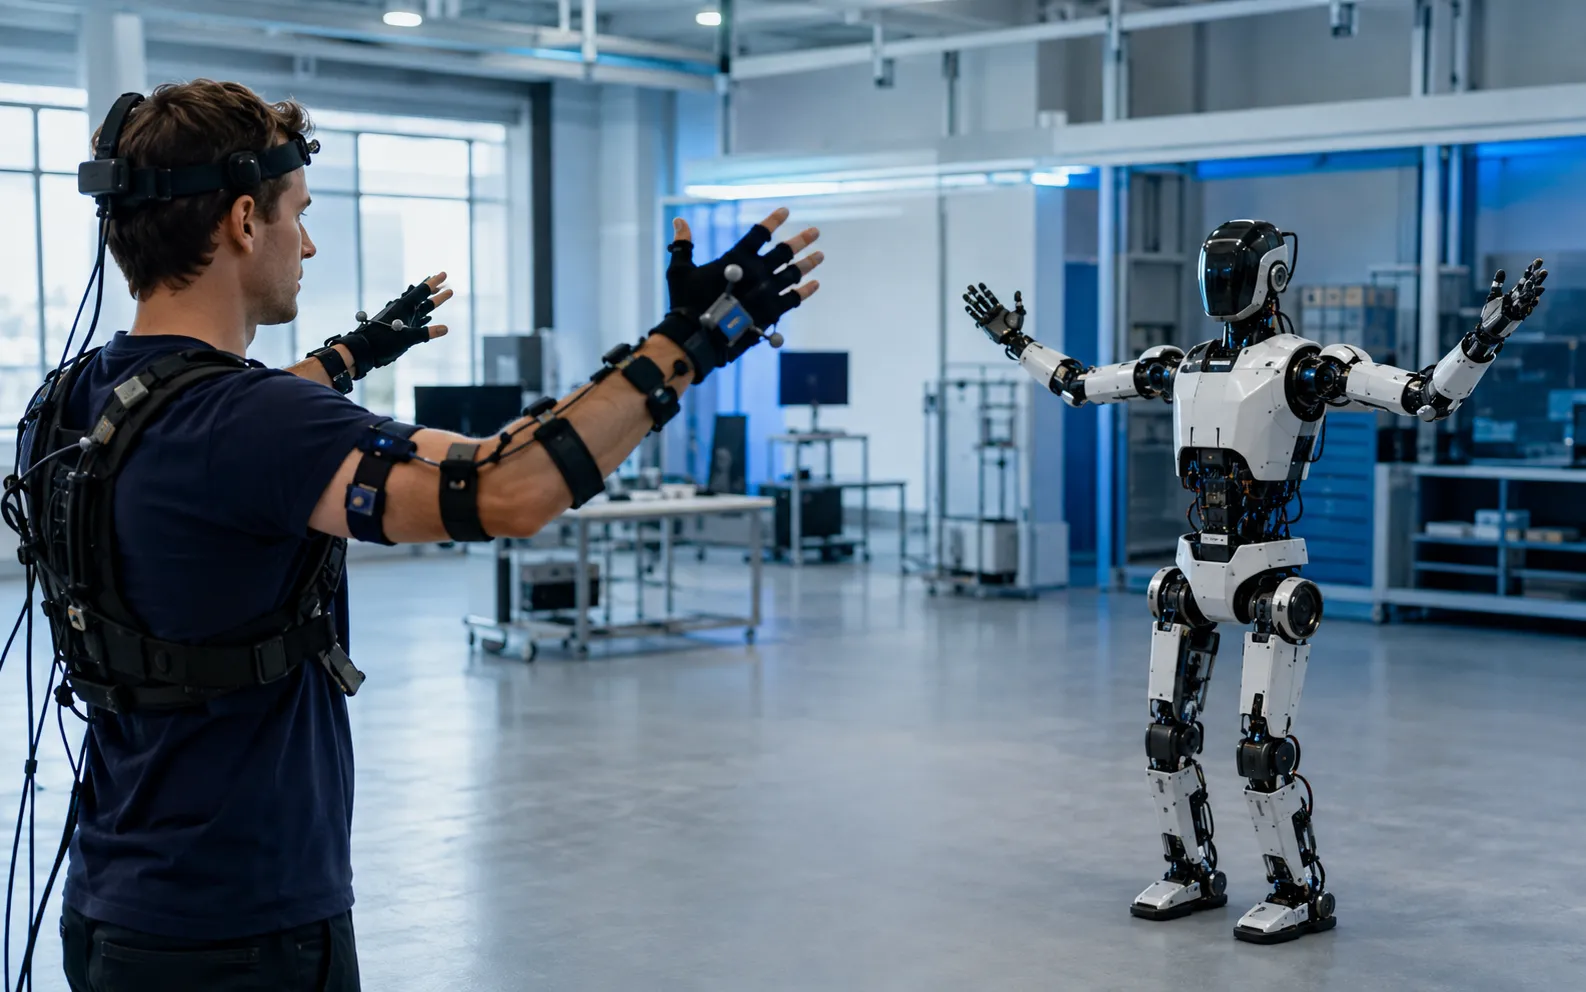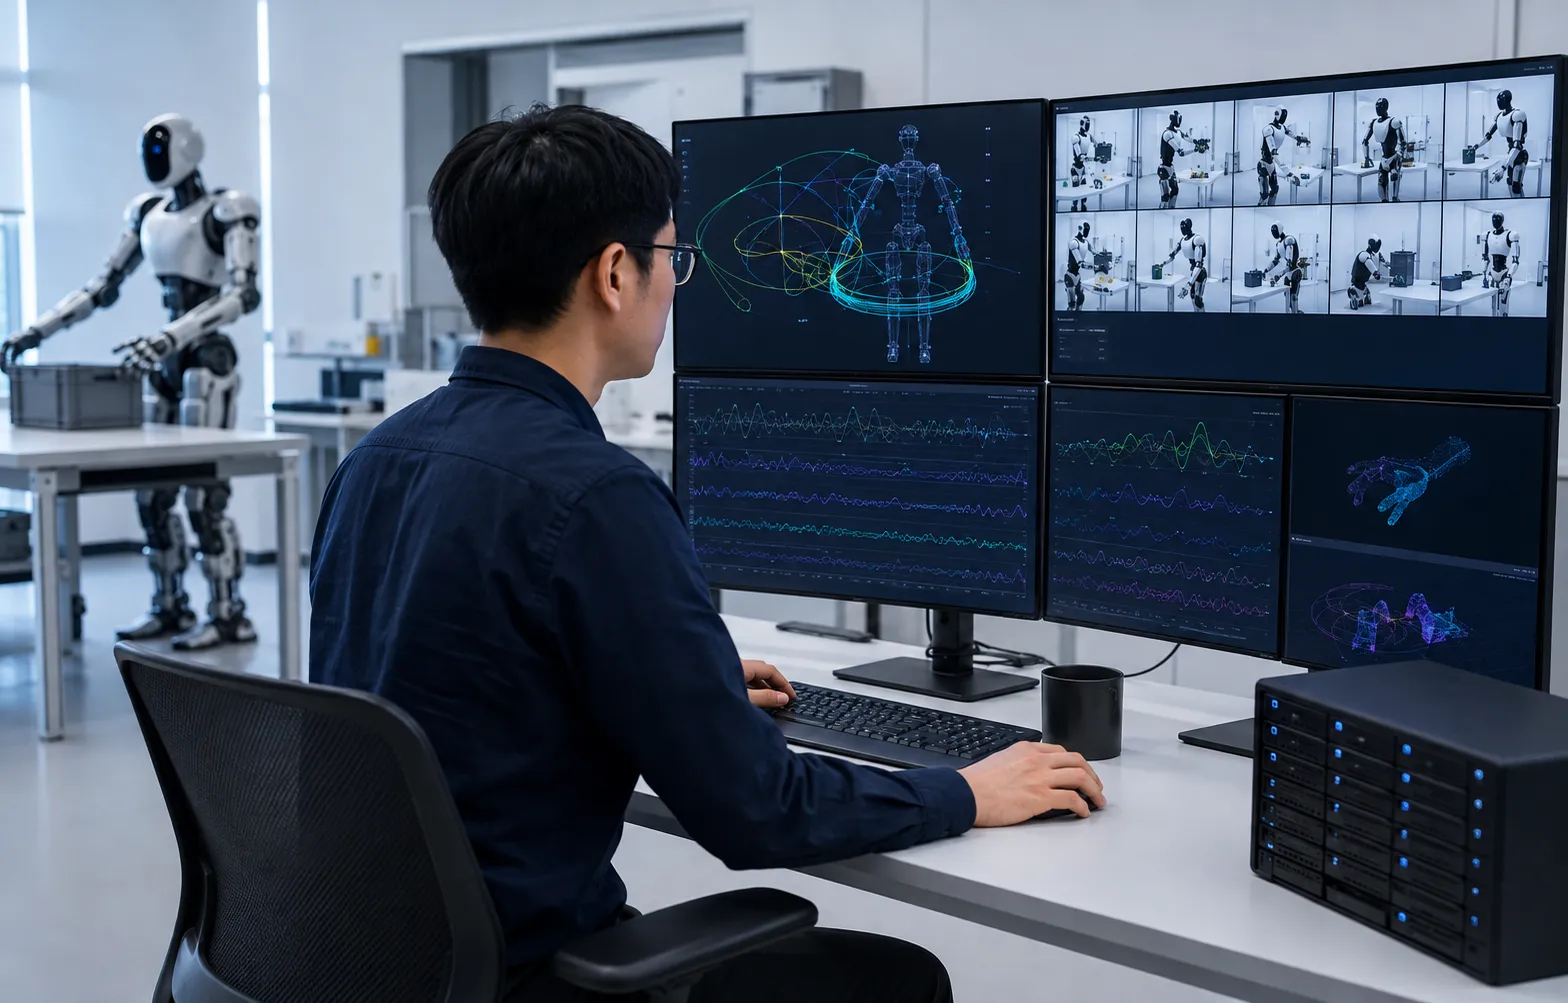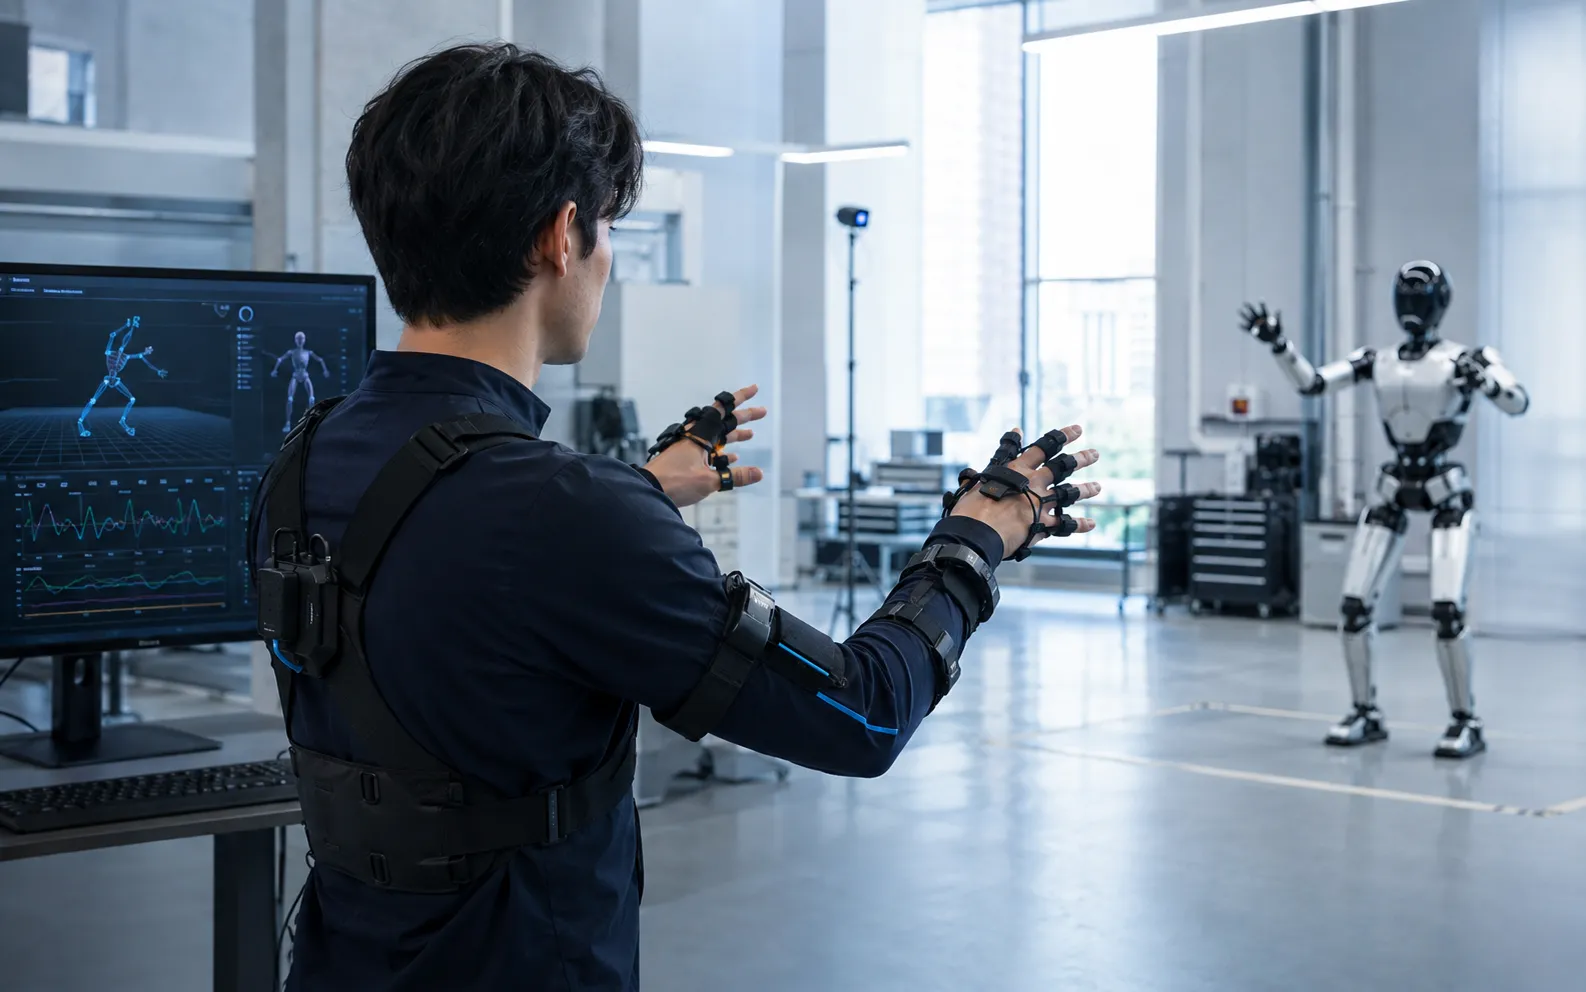
Qnbot data collection and teleoperation platform interface

Qnbot Data & TeleoperationPlatform

Data Collection Platform

Turn every robot operation into deliverable data

Operate robots. Capture real task data.

Start with a shared system for task and data management, connect teleoperation terminals to different robots, and turn real-world operations into deliverable datasets.

All workflow stories are shown in order. On wider screens, use Previous and Next to change the current story.

  1. Organize people, devices, and tasks
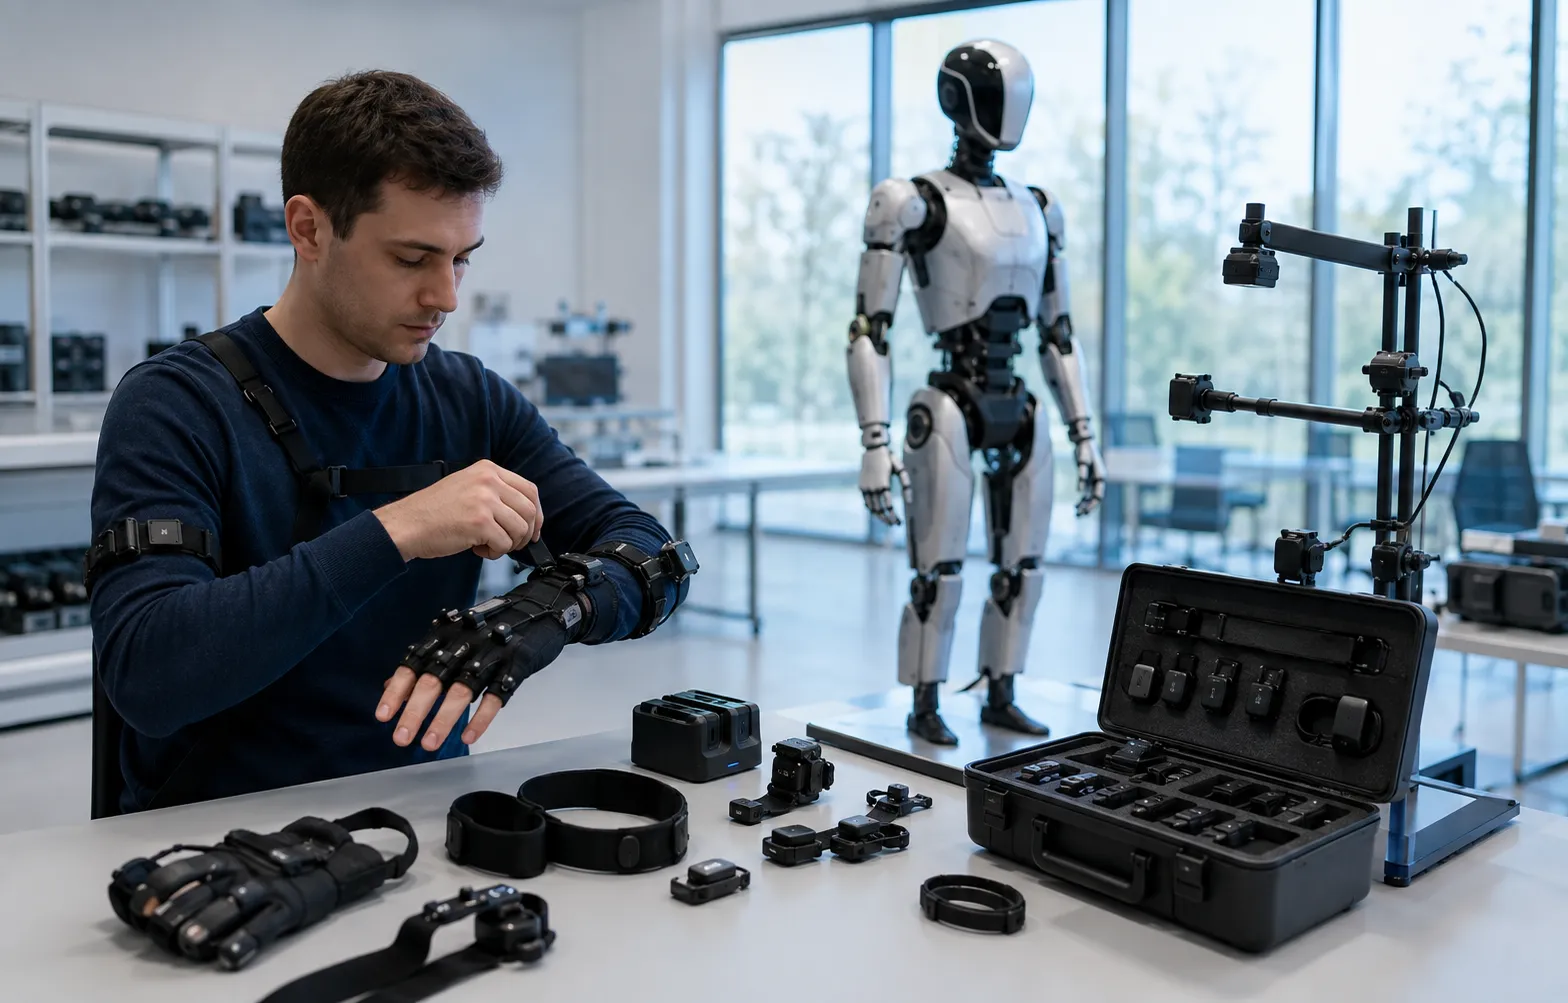
    People, device, and task management in the data collection platform

    One hub aligns operators, motion-capture devices, robots, and task requirements, giving every field session a clear objective and delivery standard.

    • Manage devices, operators, and tasks in one place
    • Configure collection targets and delivery requirements
    • Track task status and field activity
  2. Map human motion to robots

    Teleoperation interface mapping operator motion to robot execution

    The teleoperation terminal adapts to each robot and control interface, maps captured movement to commands, and streams video, status, and task events back to the operator.

    • Adapt to robot bodies and control interfaces
    • Map motion with real-time control and haptic feedback
    • Capture field video, device status, and task records
  3. Turn operations into datasets

    Task data becoming a versioned data asset after quality review

    Motion, robot state, field video, and task events are synchronized in one task pipeline. Quality checks and version management turn each session into a traceable, reusable dataset ready for standardized delivery.

    • Synchronize multimodal task data
    • Check data quality and trace anomalies
    • Manage dataset versions and standardized delivery

Qnbot Data Workflow

From human motionto robot executionto reusable data.

  1. Motion Input

    Wearable hardware captures hand and upper-body movement

  2. Robot Integration

    The teleoperation terminal maps motion to robot control interfaces

  3. Task Execution

    Control robots in real time while streaming video and system status

  4. Data Capture

    Record motion, robot state, video, and task events

  5. Standardized Delivery

    Run quality checks, manage versions, and deliver datasets

Connect every tool in one workflow.

  1. Integrate robots faster

    Configure terminals for different robots and control interfaces, reducing repeated integration work.

  2. Run collection reliably

    Keep operators, devices, robots, and field activity synchronized in one system.

  3. Deliver consistent embodied data

    Turn real-world operations into datasets that can be reviewed, traced, and versioned.

Please leave your contact information and task requirements, and we will arrange follow-up communication accordingly.

Topic: Data collection solution · Product: Qnbot Data & Teleoperation Platform