Four core capabilities
Capture natural upper-body motion
High-speed joint capture
- 14 bit
- Pose resolution
- 1000 Hz
- Sampling rate
- Millisecond-level
- Human-to-robot mapping
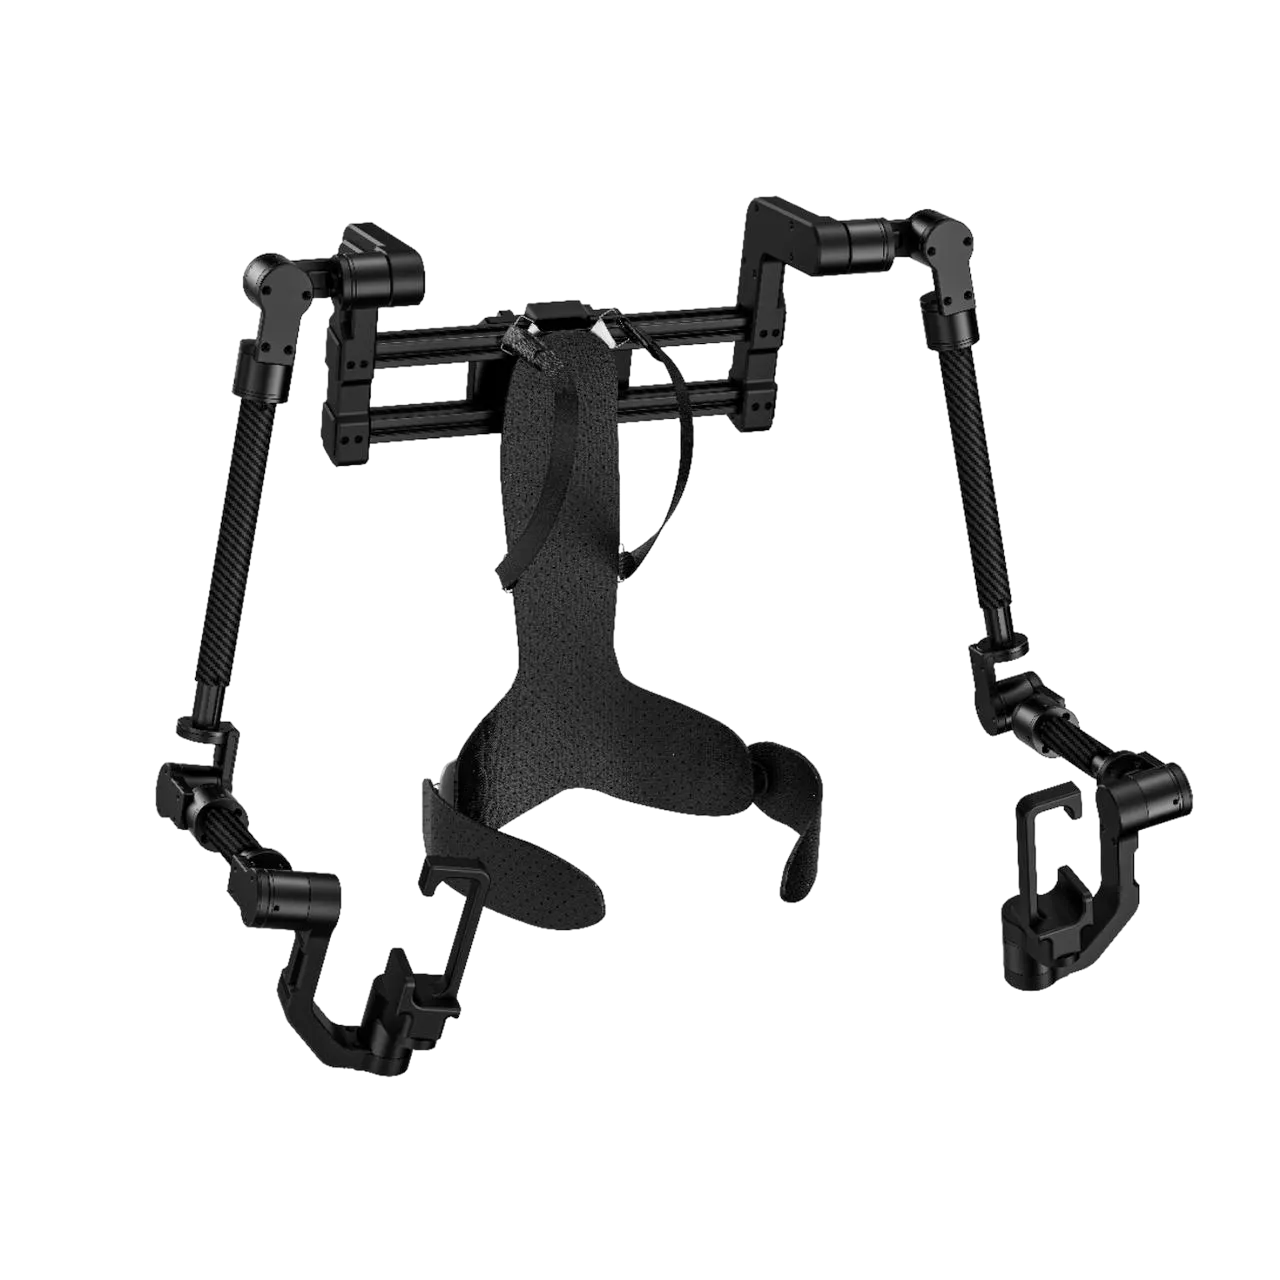
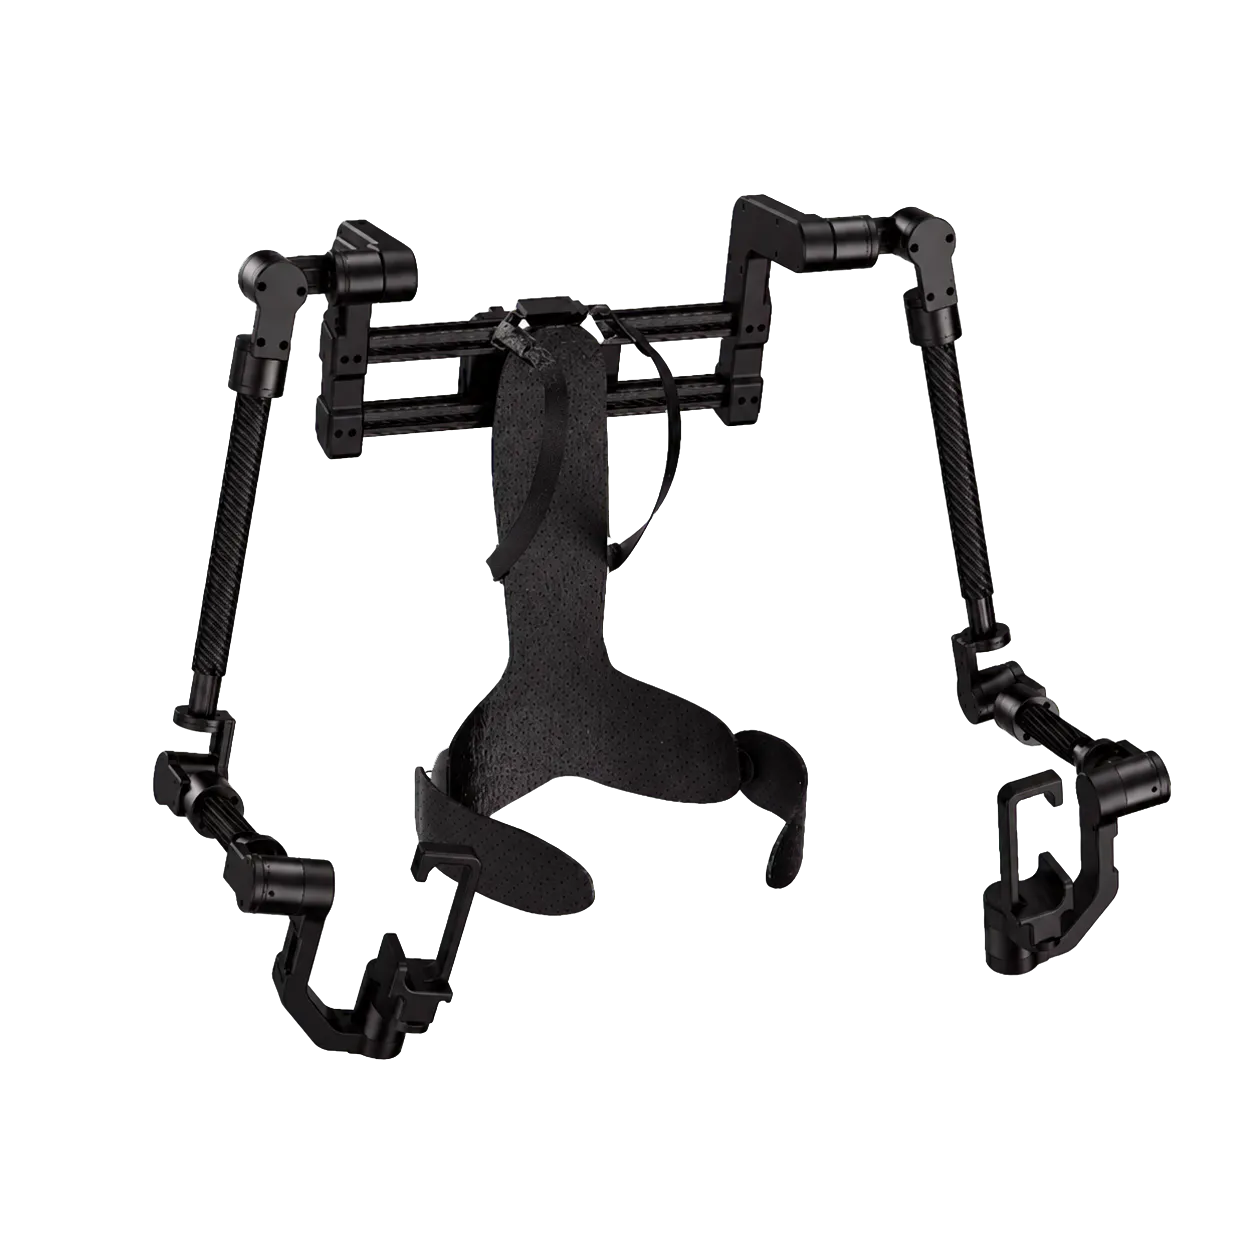
14-joint dual-arm design
- 7 per arm
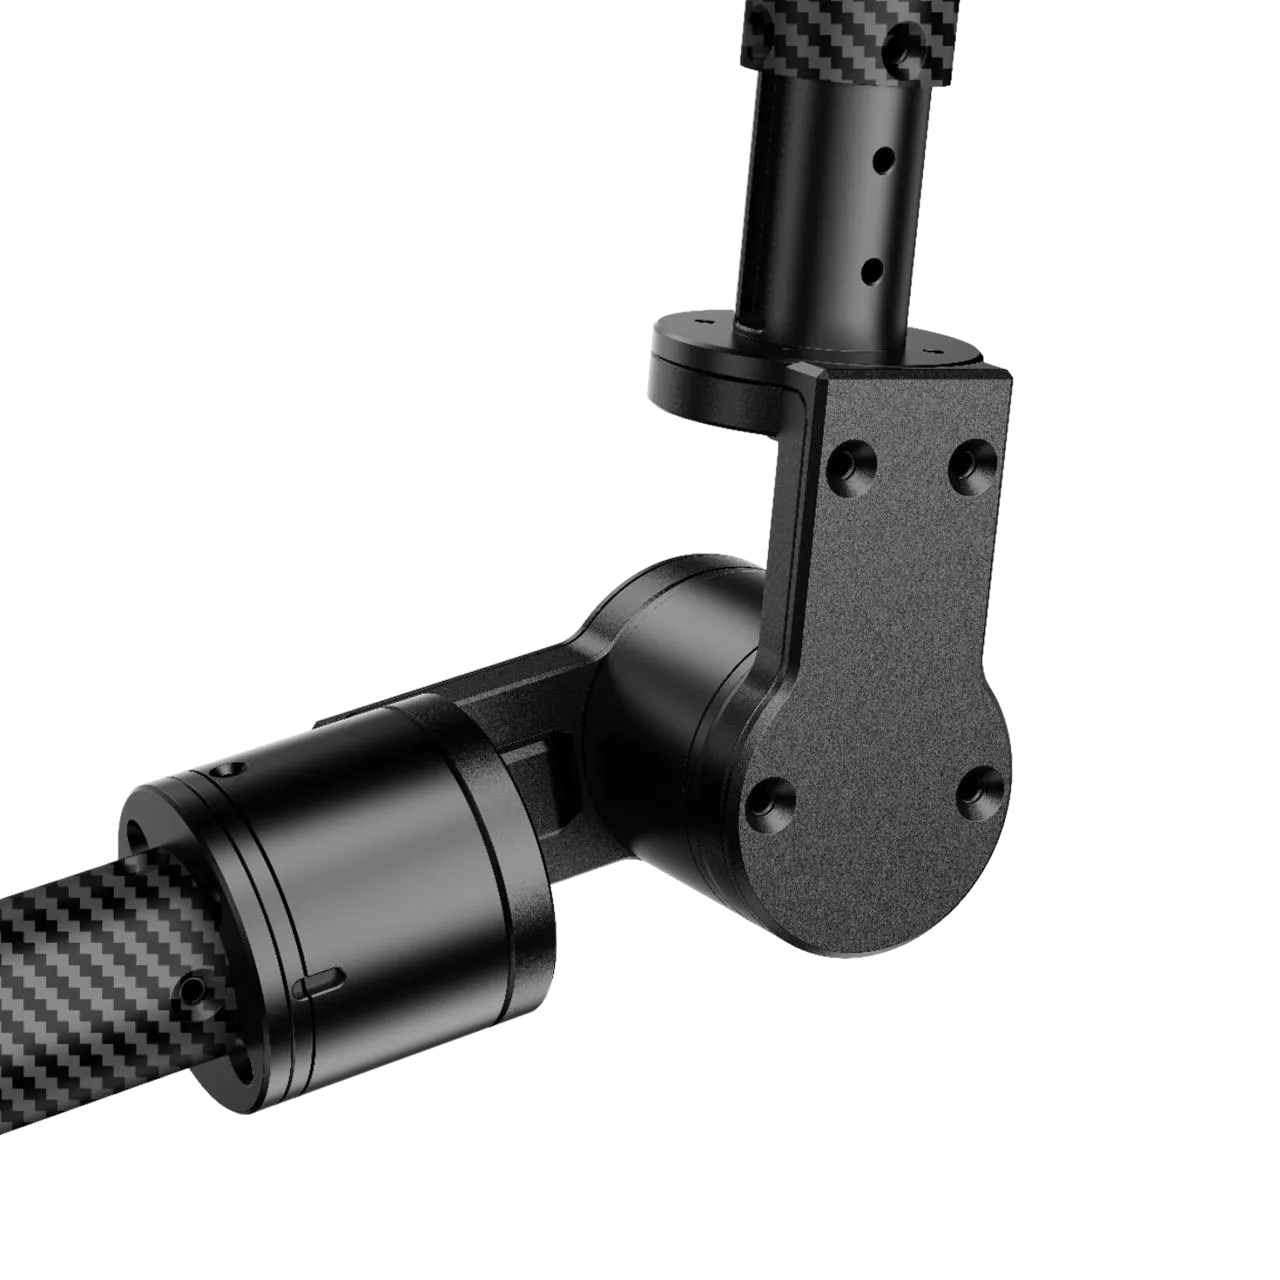
- Articulated joints
- Carbon fiber
- Telescopic links
- Anthropomorphic
- Configuration
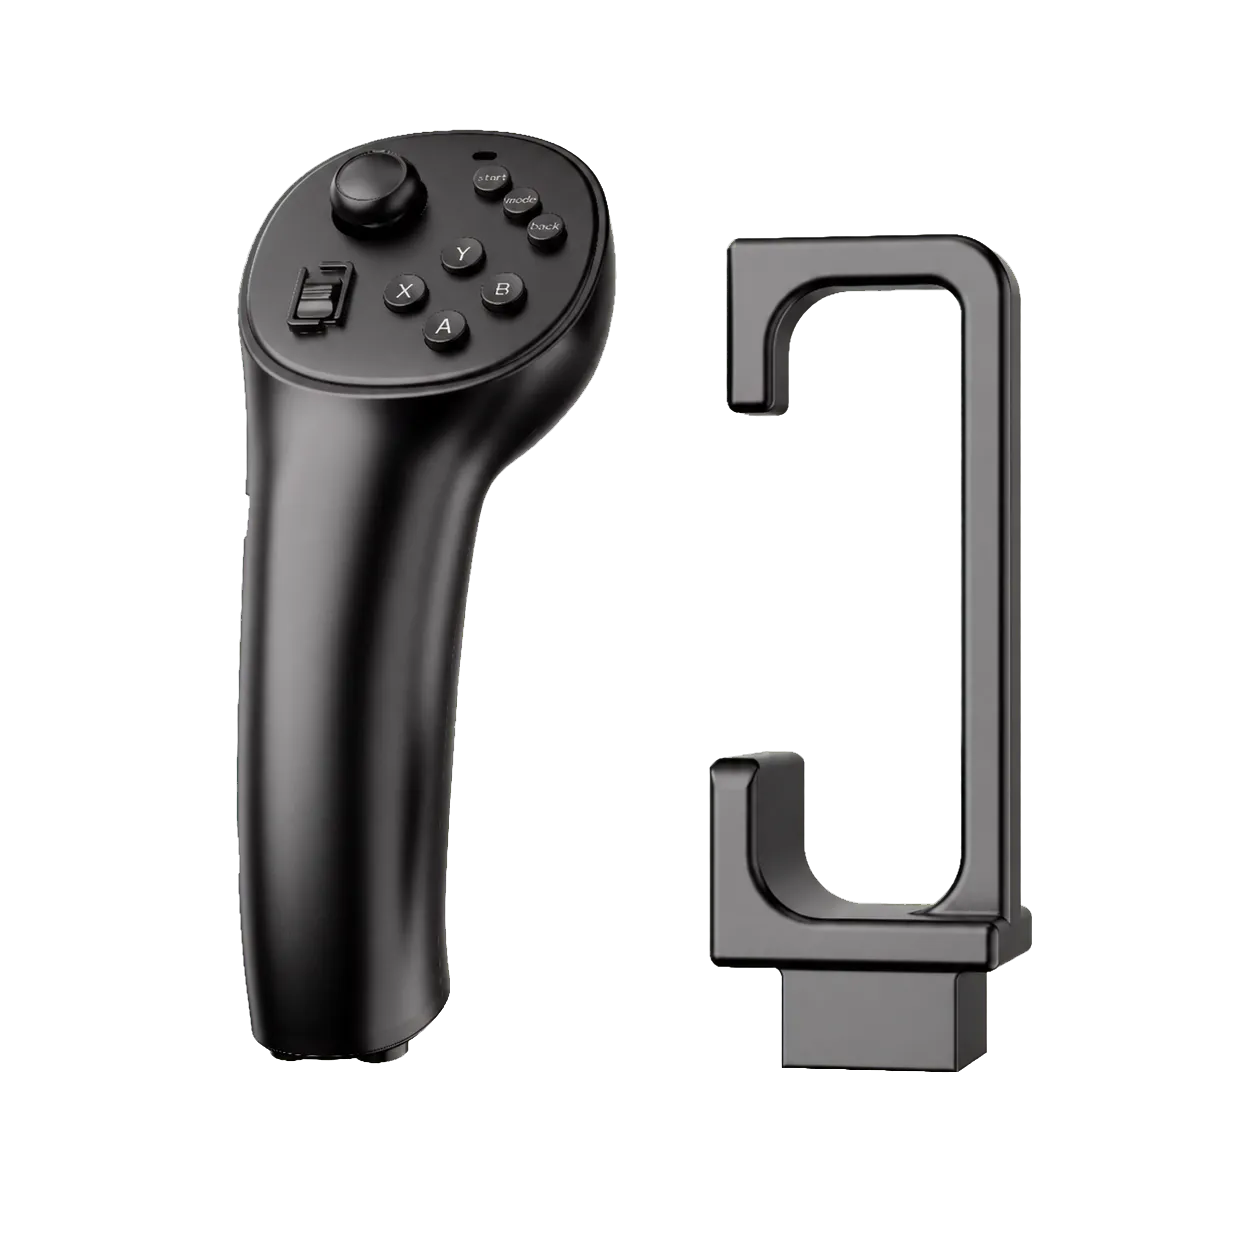
Multifunction controllers
- TMR
- Dual-axis joystick
- 500 Hz
- Effective input rate
- Programmable
- Custom buttons
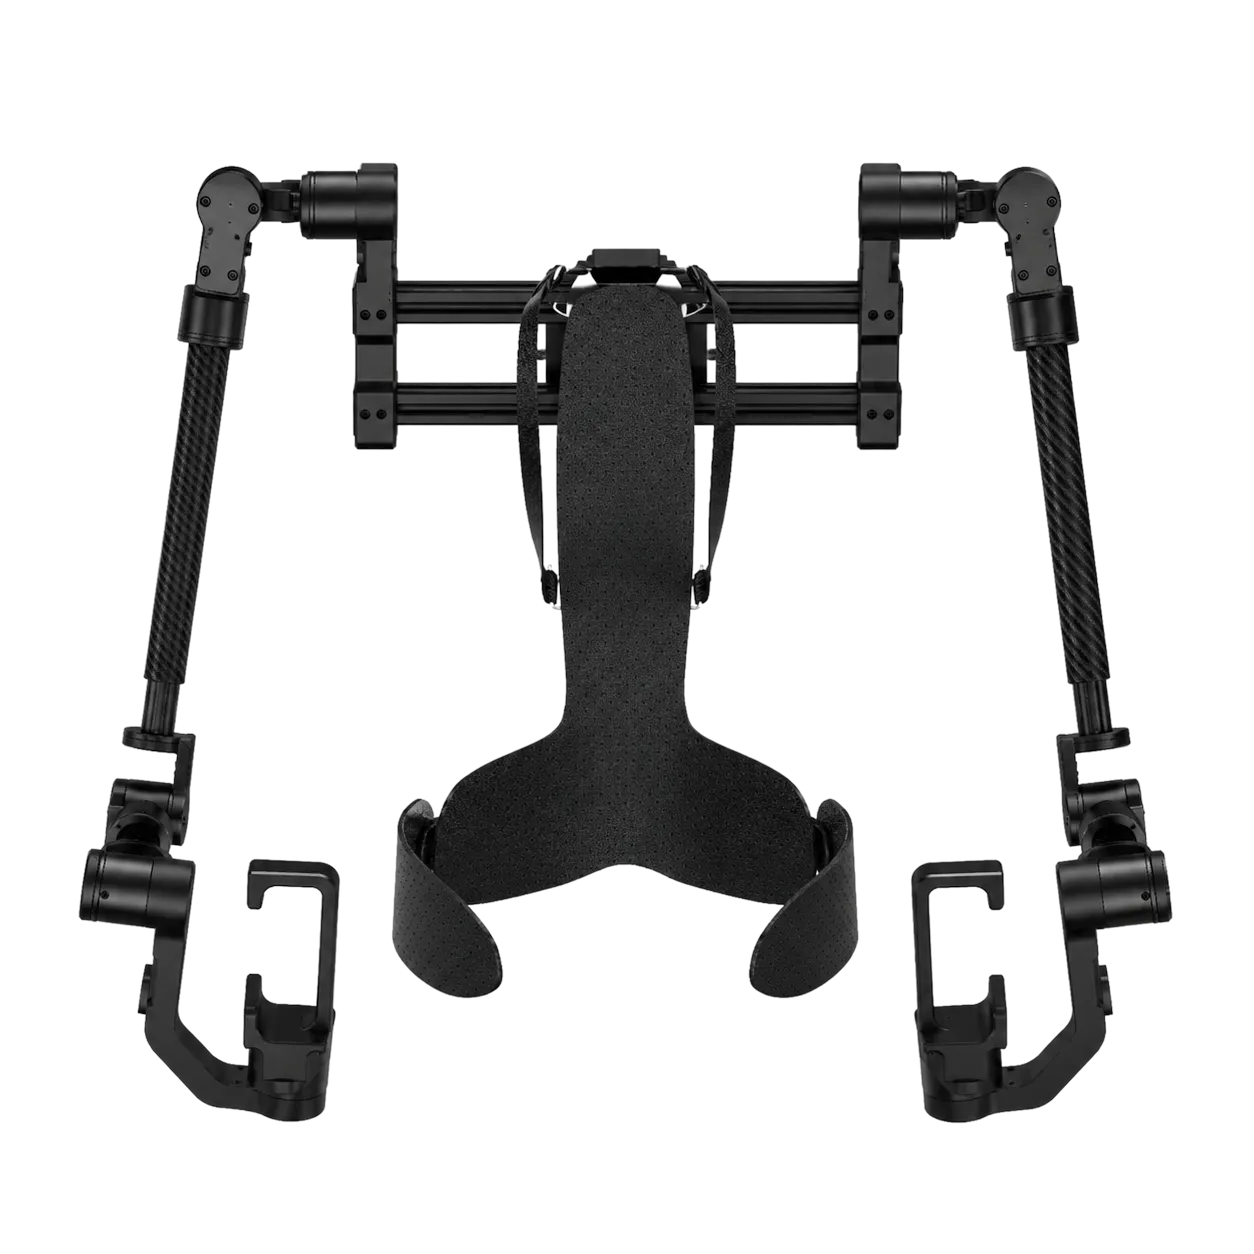
Lightweight, adjustable structure
- 2.6 kg
- Typical unit weight
- Ergonomic
- Harness system
- Gimbal
- Wrist mechanism
Precise control that mirrors every move
High-frequency, stable motion capture supports fine manipulation, remote operation, motion imitation, and data collection for robot teaching and human–robot collaboration.
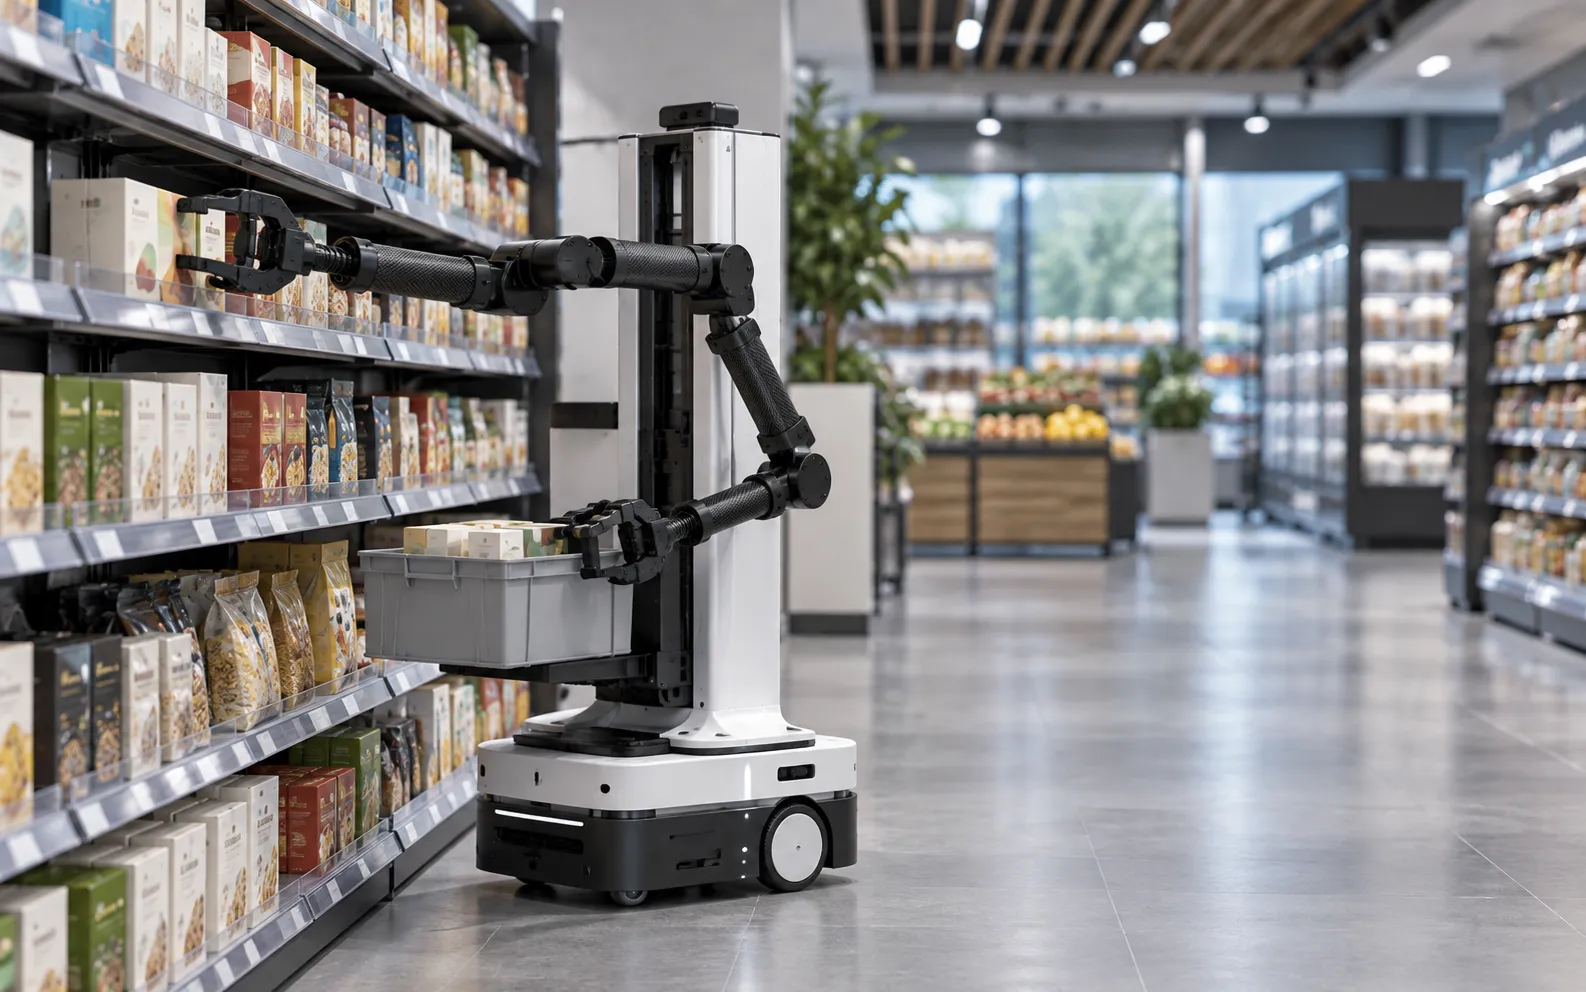
Supermarkets 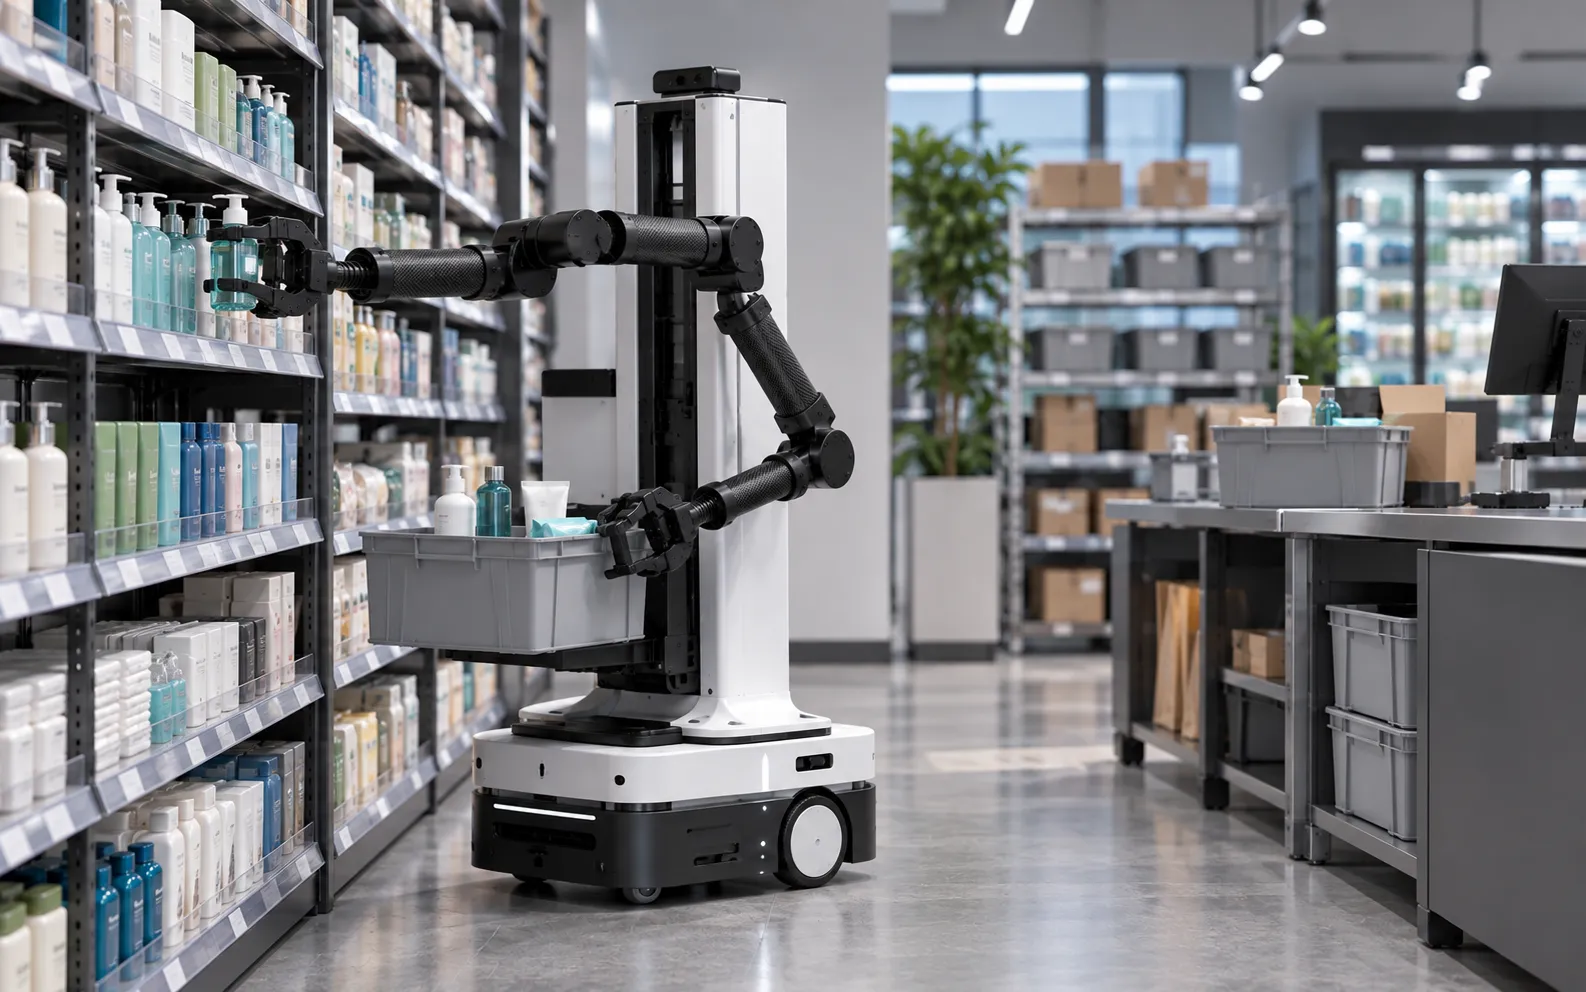
On-Demand Retail 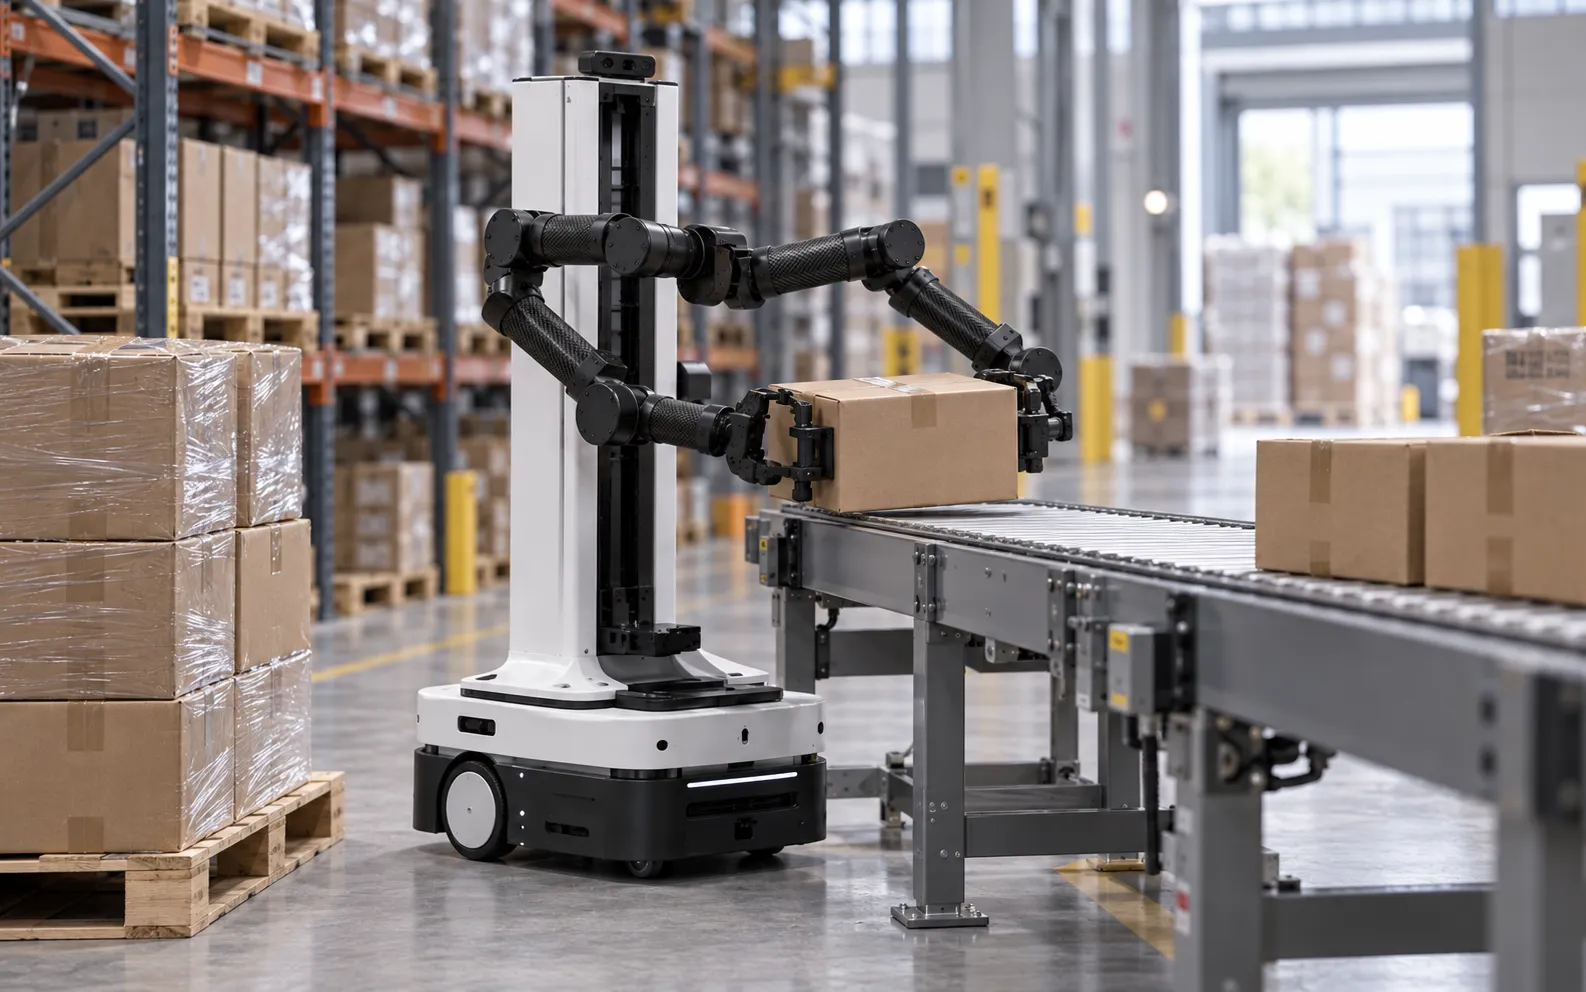
Logistics & Warehousing 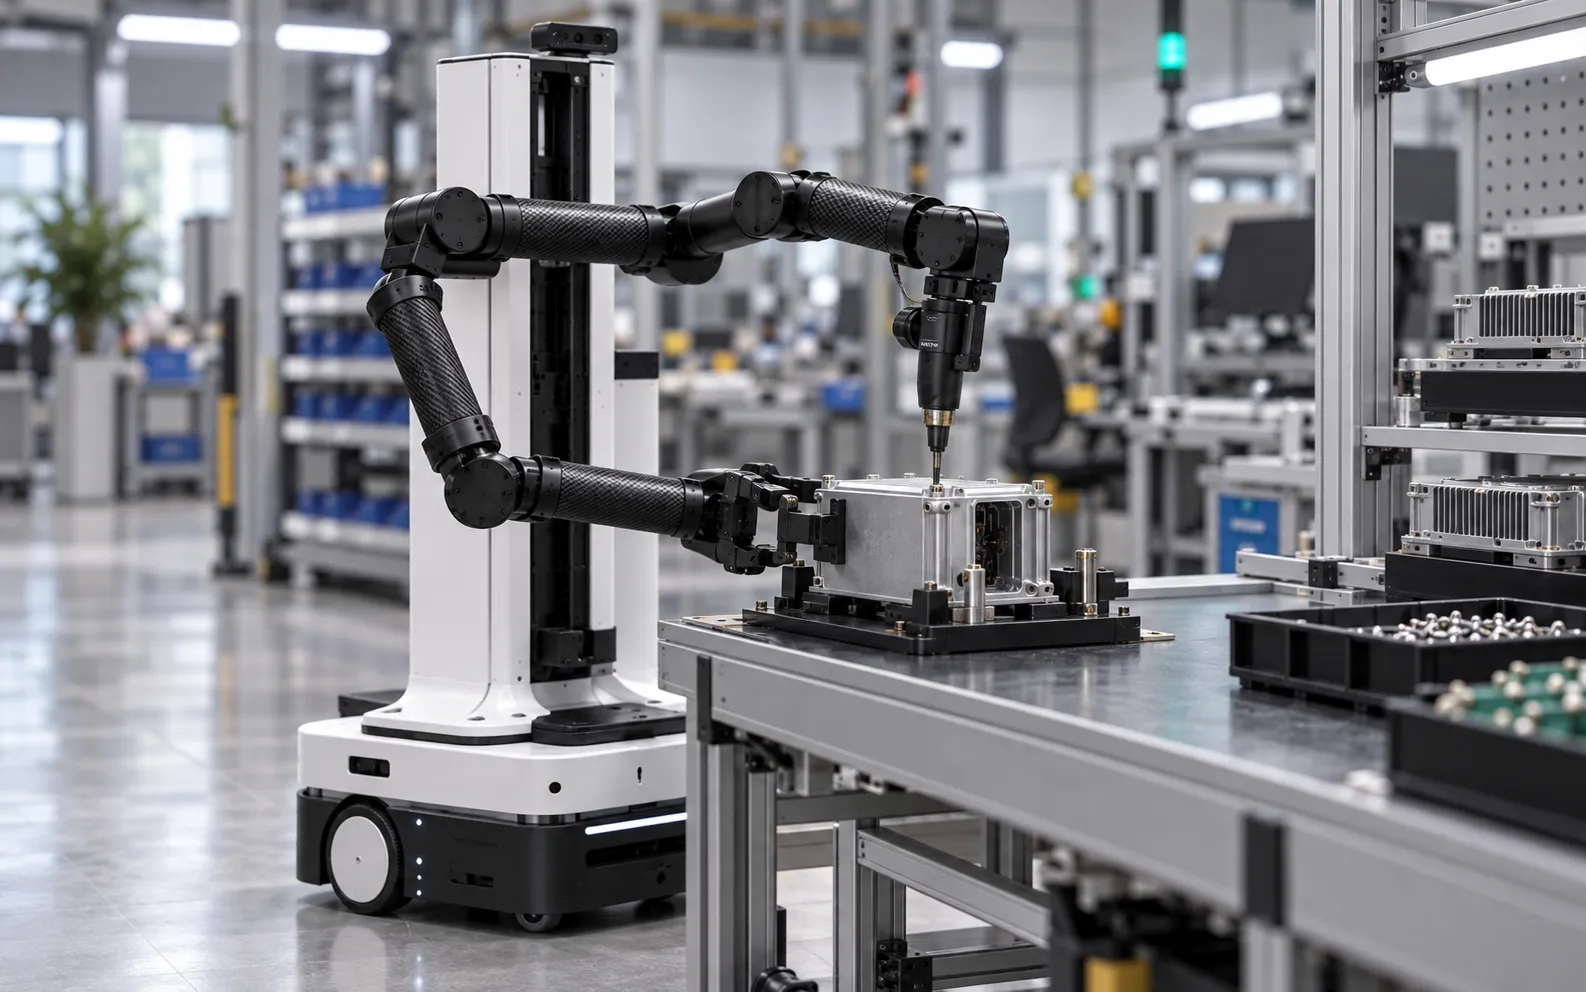
Industrial Assembly 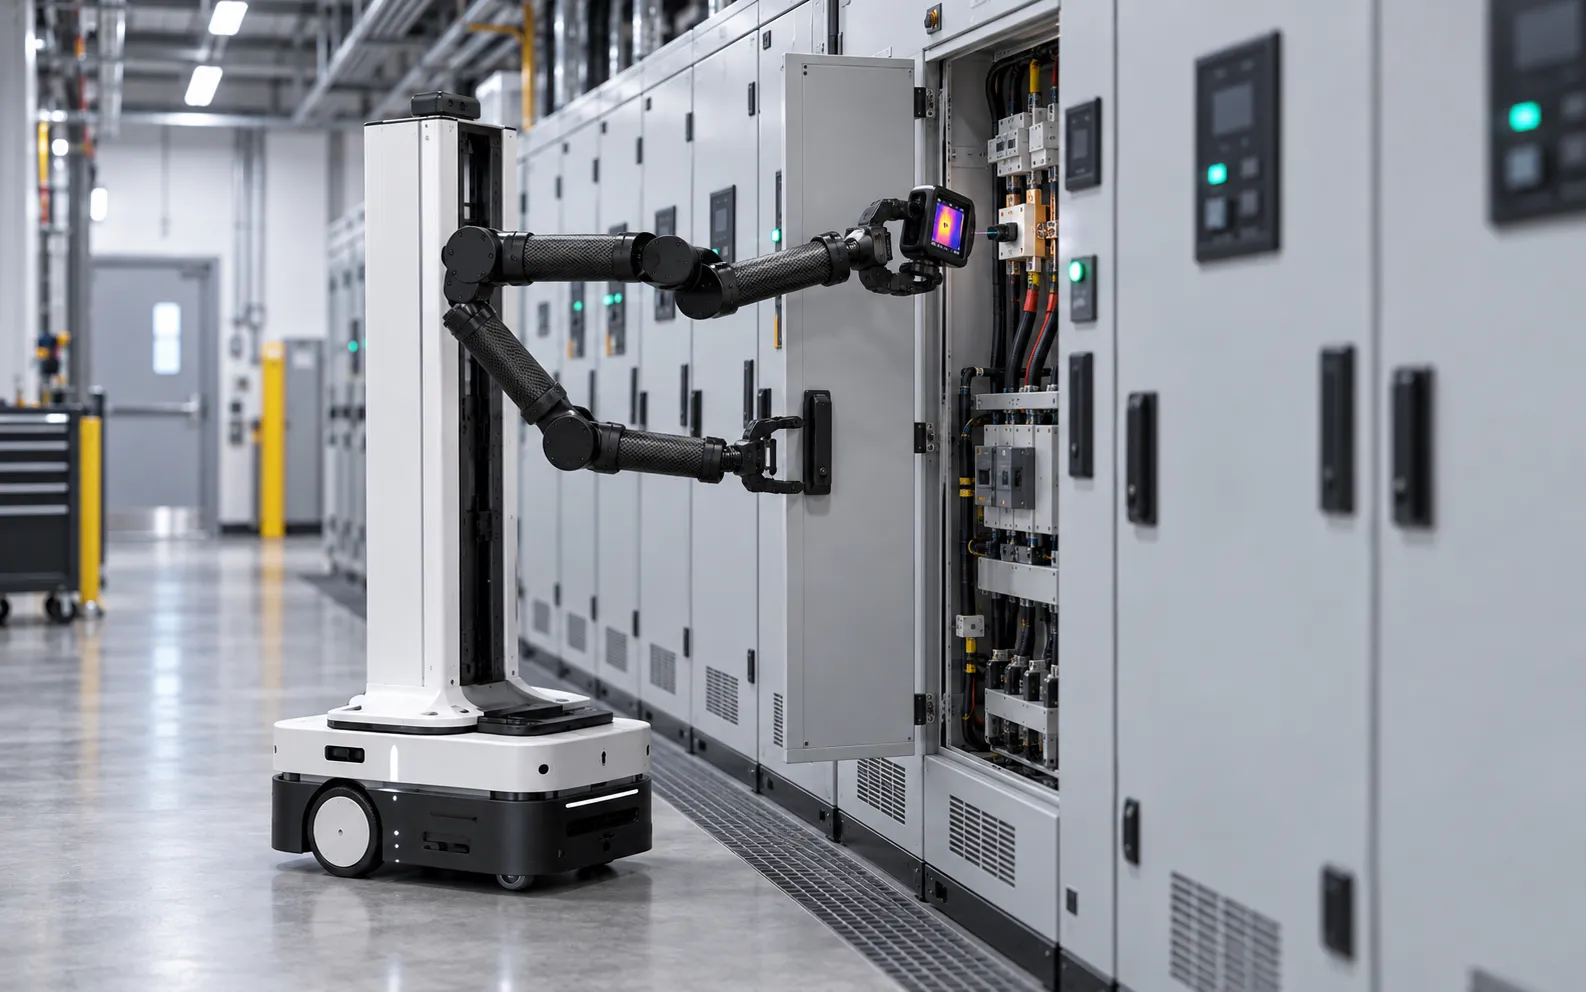
Routine Inspection 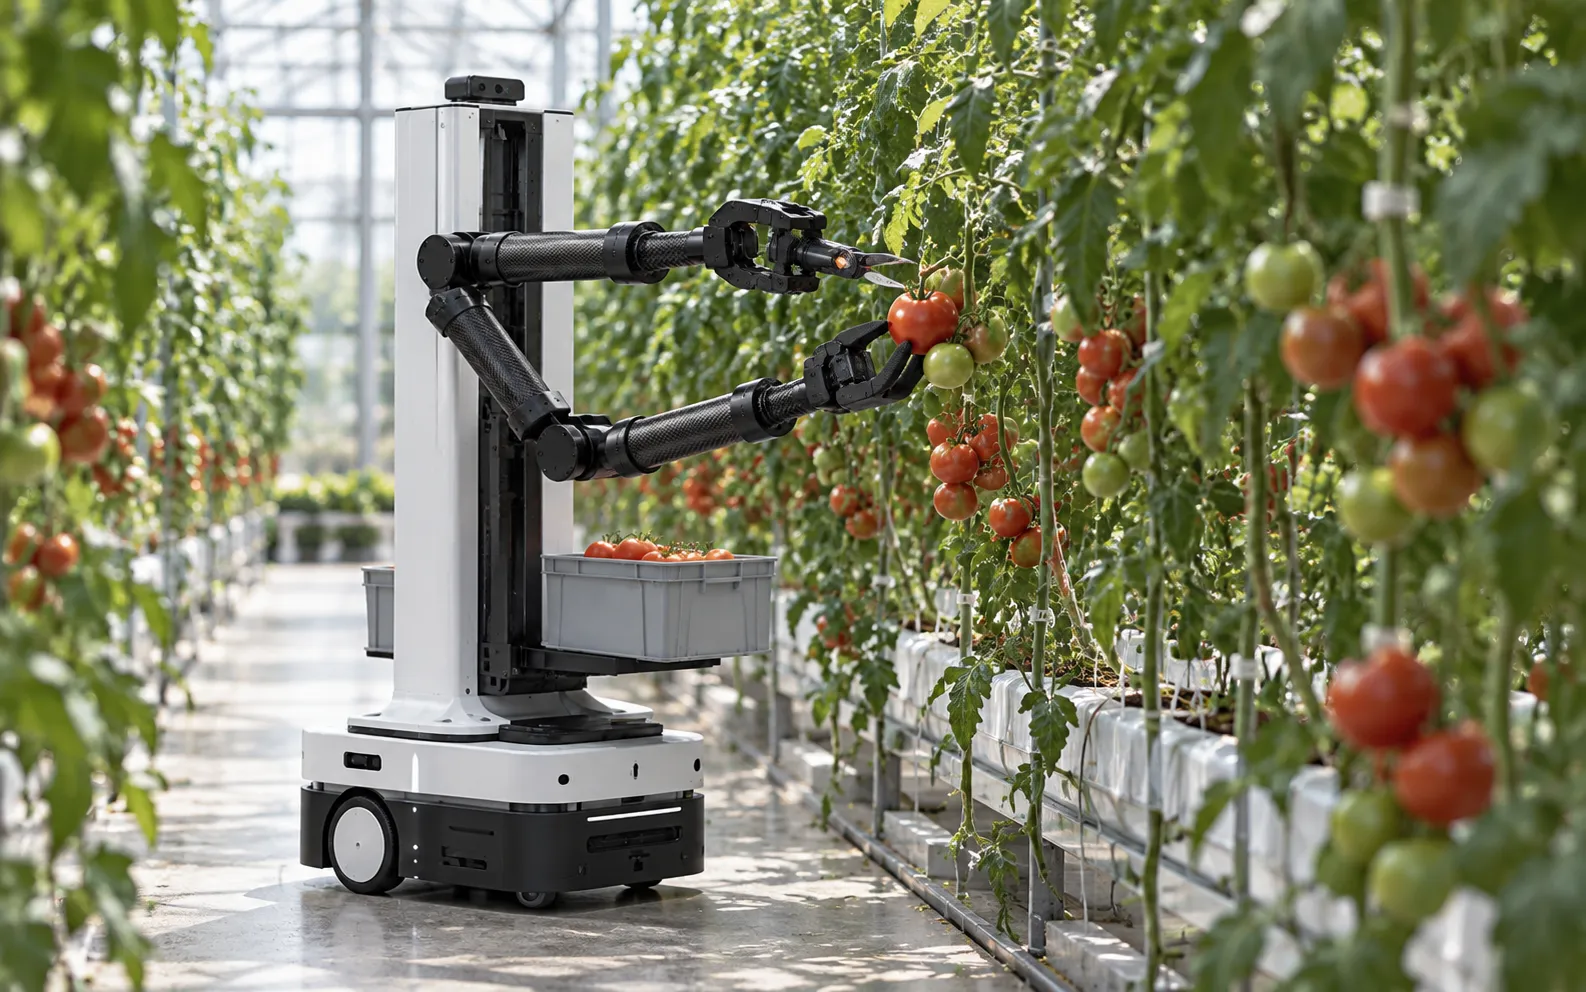
Agriculture 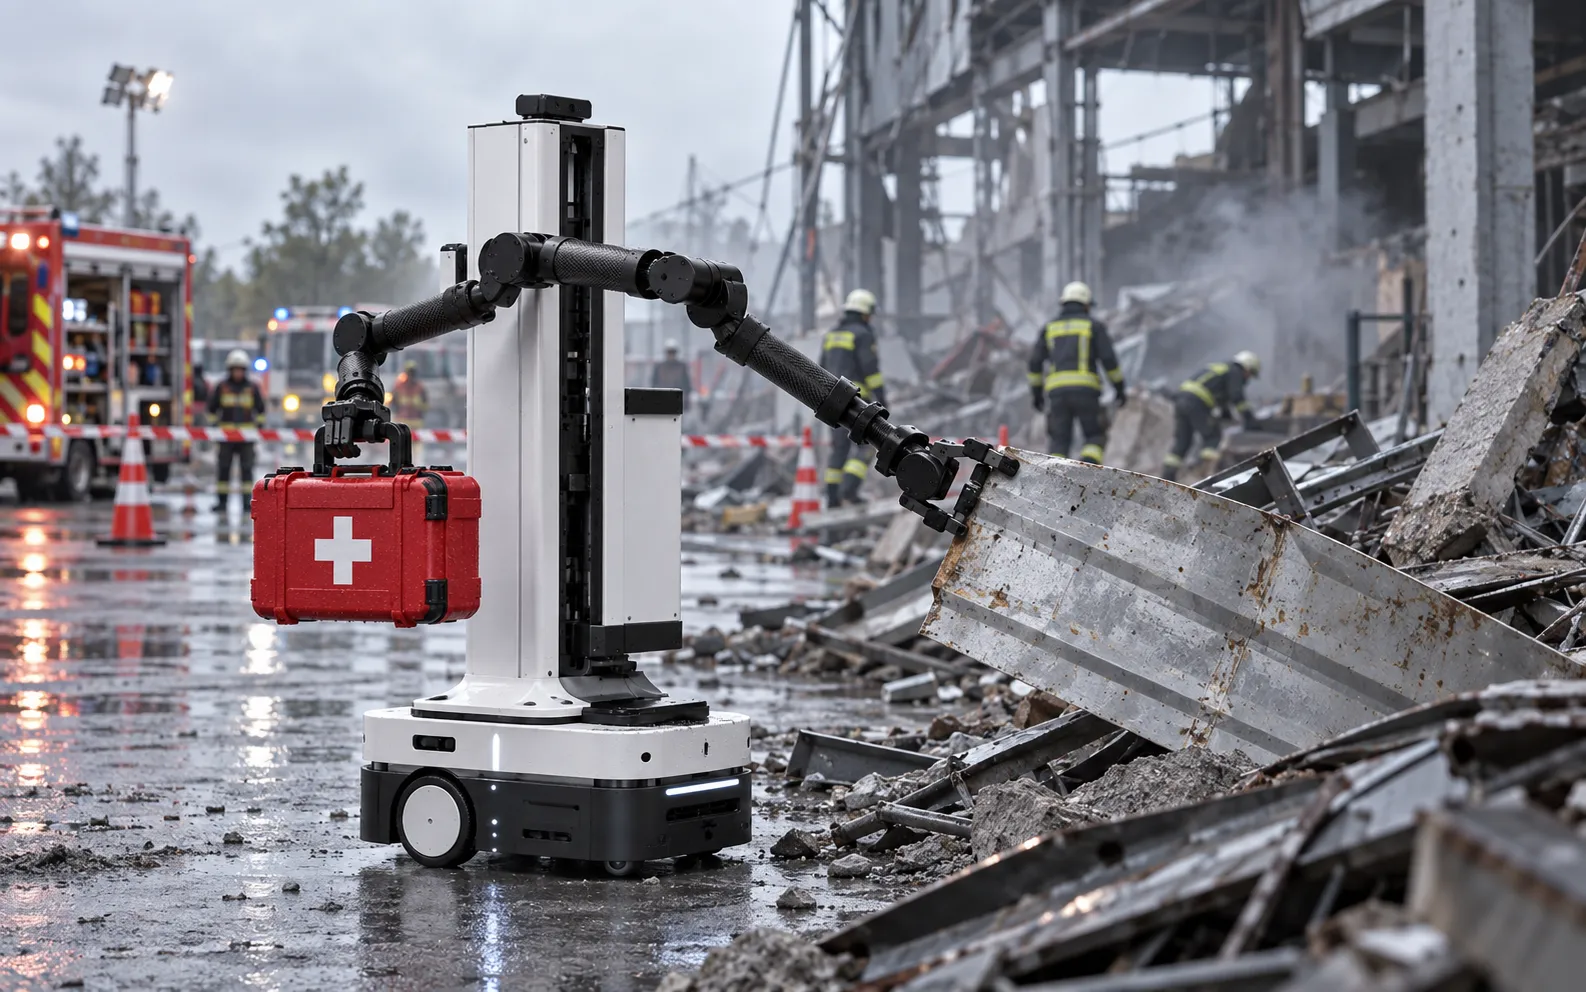
Emergency Response 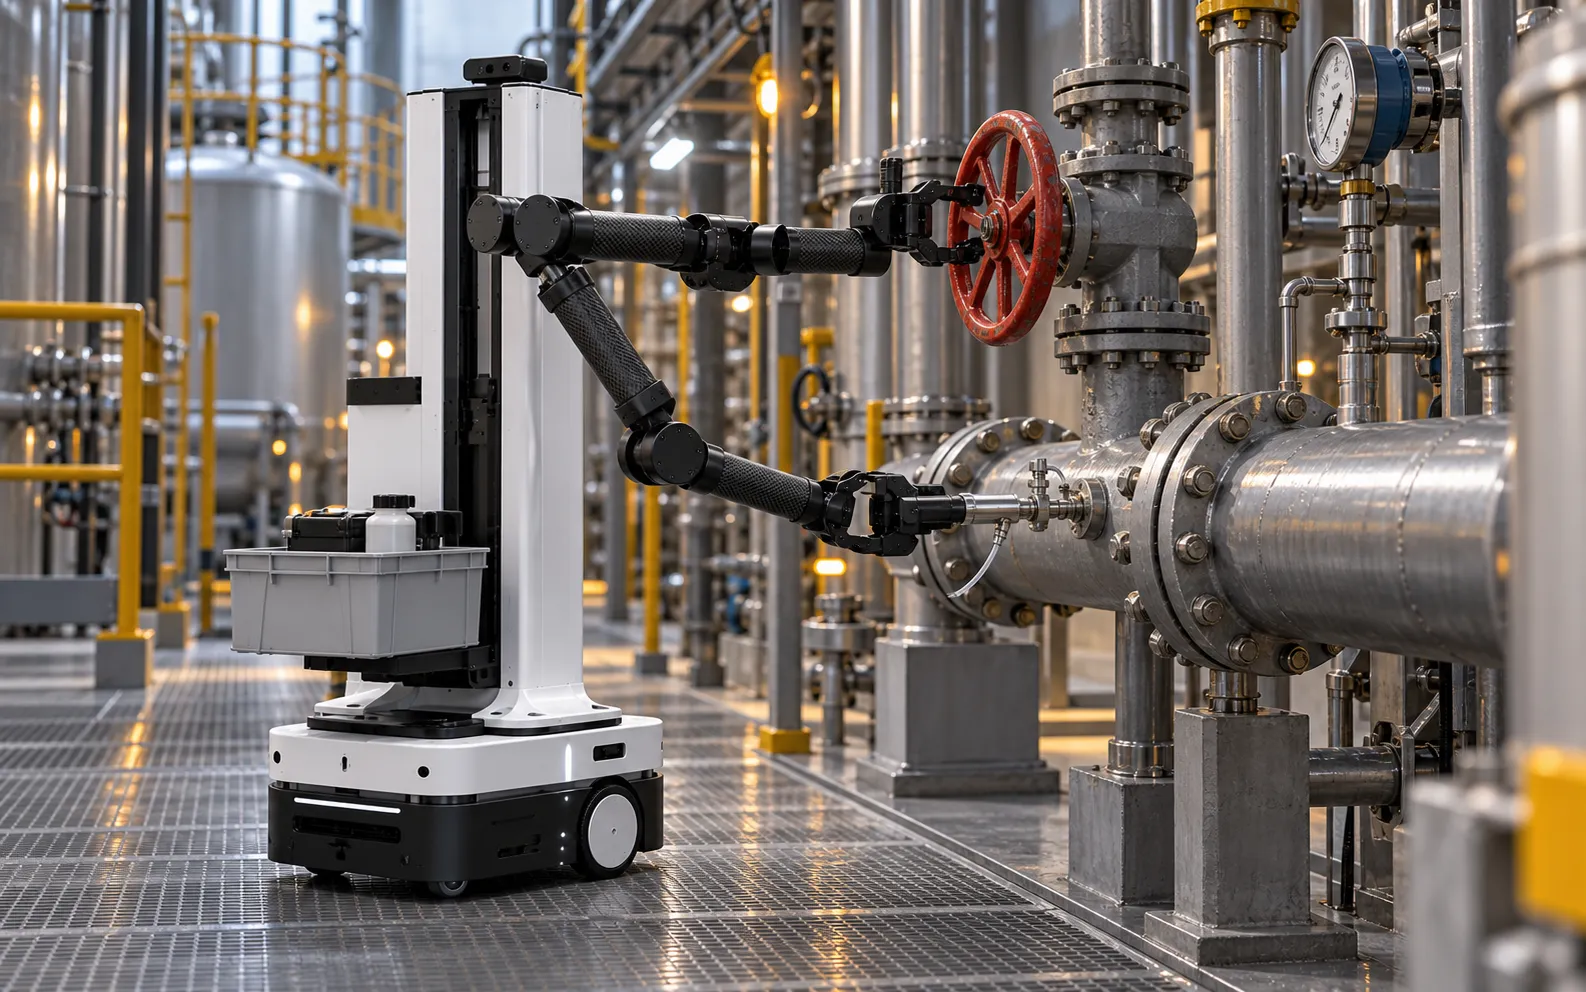
Hazardous Operations 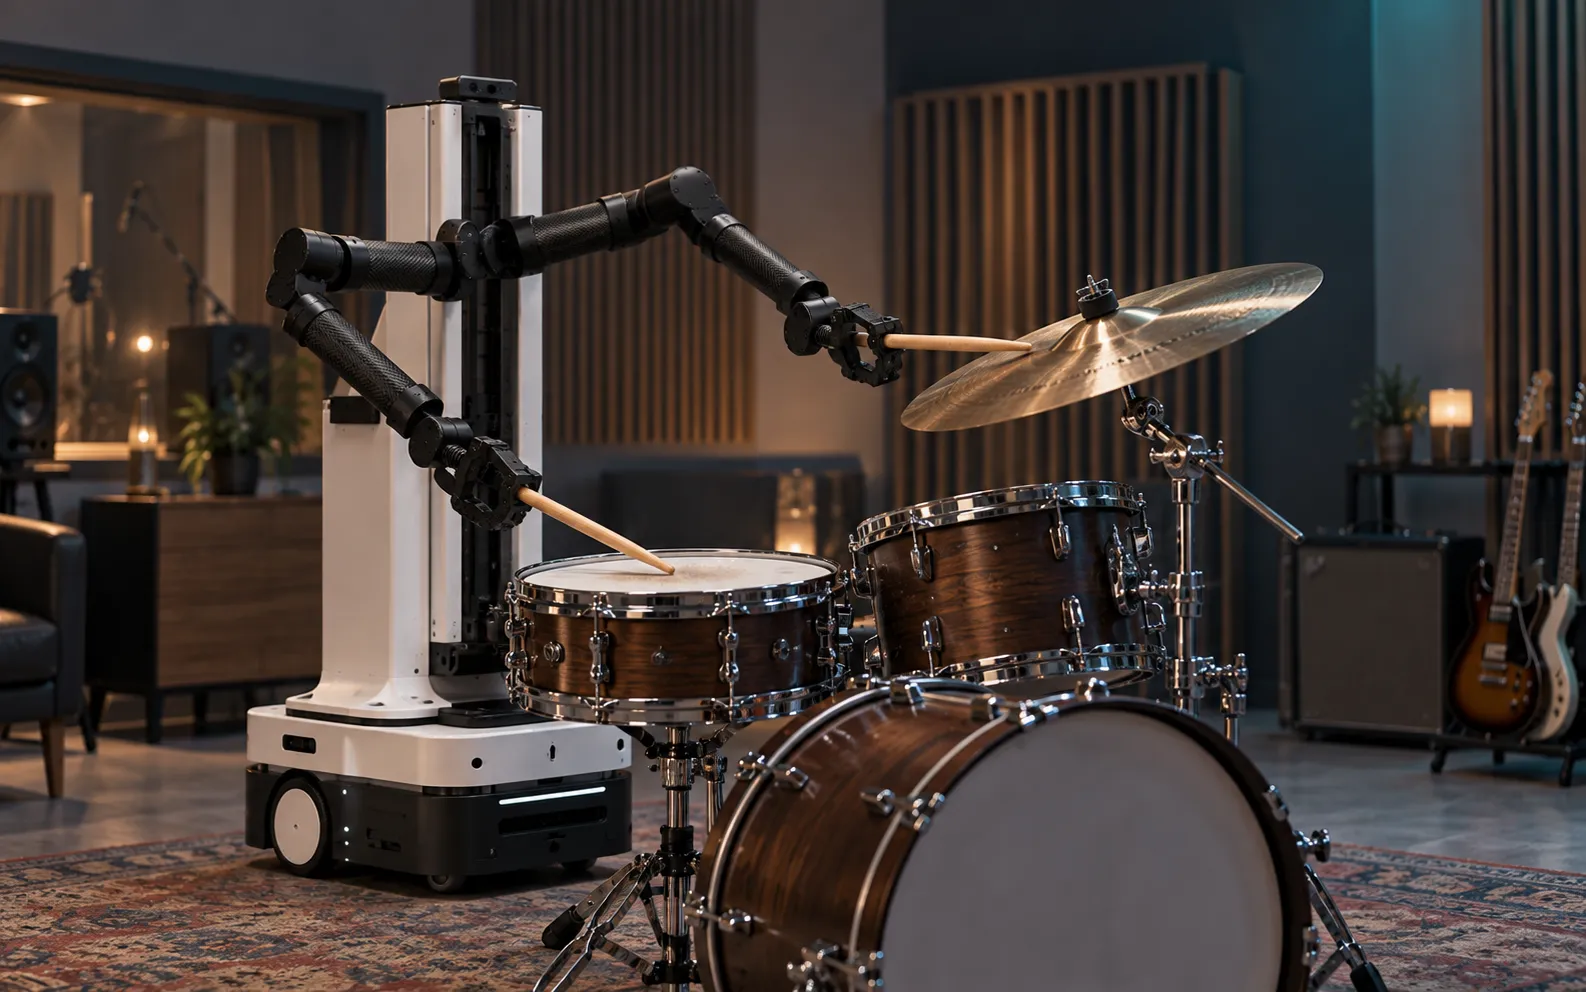
Creative Performance
Technical specifications
Compare structure, interfaces, and performance
Hardware & structure
- Back mounting
- Parallel shoulder bracket with ergonomic harness system
- Power interface
- Type-C PD 5 V
- Data interface
- Type-C
- Integration
- Multi-platform pose mapping and isomorphic control
- Supported configuration
- Anthropomorphic
- Joint weight
- Approx. 60 g
- Typical unit weight
- 2.6 kg (excluding harness)
- Joint configuration
- 14 articulated joints (7 per arm)
- Controllers
- 2
- Analog channels
- Haptic trigger and TMR dual-axis joystick
- Digital channels
- Joystick press, 9 programmable buttons, and switch
- Back / external sensor (optional)
- IMU
Performance & sampling
- Joint data resolution
- 14 bit
- Maximum theoretical joint data rate
- 1000 Hz
- Data output rate
- 200 Hz / 500 Hz
- Maximum effective joystick / trigger rate
- 200 Hz (after filtering)
- Mechanical limits
- J1, J2, J3, J5: 300°; J4, J6, J7: 180°
- Link configuration
- Adjustable telescopic carbon-fiber links
Package contents & options
See what is included and optional